Robotics Software Engineer · Bangkok

Paing Thet Ko

Modern, reliable robotics systems from perception to control, for smarter machines.

gait static walk · walk
phase 0.00
vx 0.00 m/s
live gait generators
contact ■ ■ ■ ■ · ■ ■click to change gait

Experience.

Two years turning research into robots that walk.

Dec 2024 — Present

General Magic (Thailand)

Robotics Software Engineer

Humanoid bipedal legs

Reinforcement-learning walking policies trained in Isaac Lab and deployed zero-shot on hardware, through a real-time ROS 2 control loop and 2000 Hz CAN.

Bio-inspired feline robots

CPG gait generation, an agentic high-brain / low-brain control architecture, and visual-inertial state estimation.
Apr — Jun 2024

Siam NSK Steering Systems

Assistant Engineer

Fanuc and Dobot automation on the production line.

Feb — Jun 2022

Ko Tine Thin

Junior Web Developer

Backend APIs in TypeScript and Postgres for a non-profit learning platform.

Projects.

Machines I have built end to end, from a sketch to a field test.

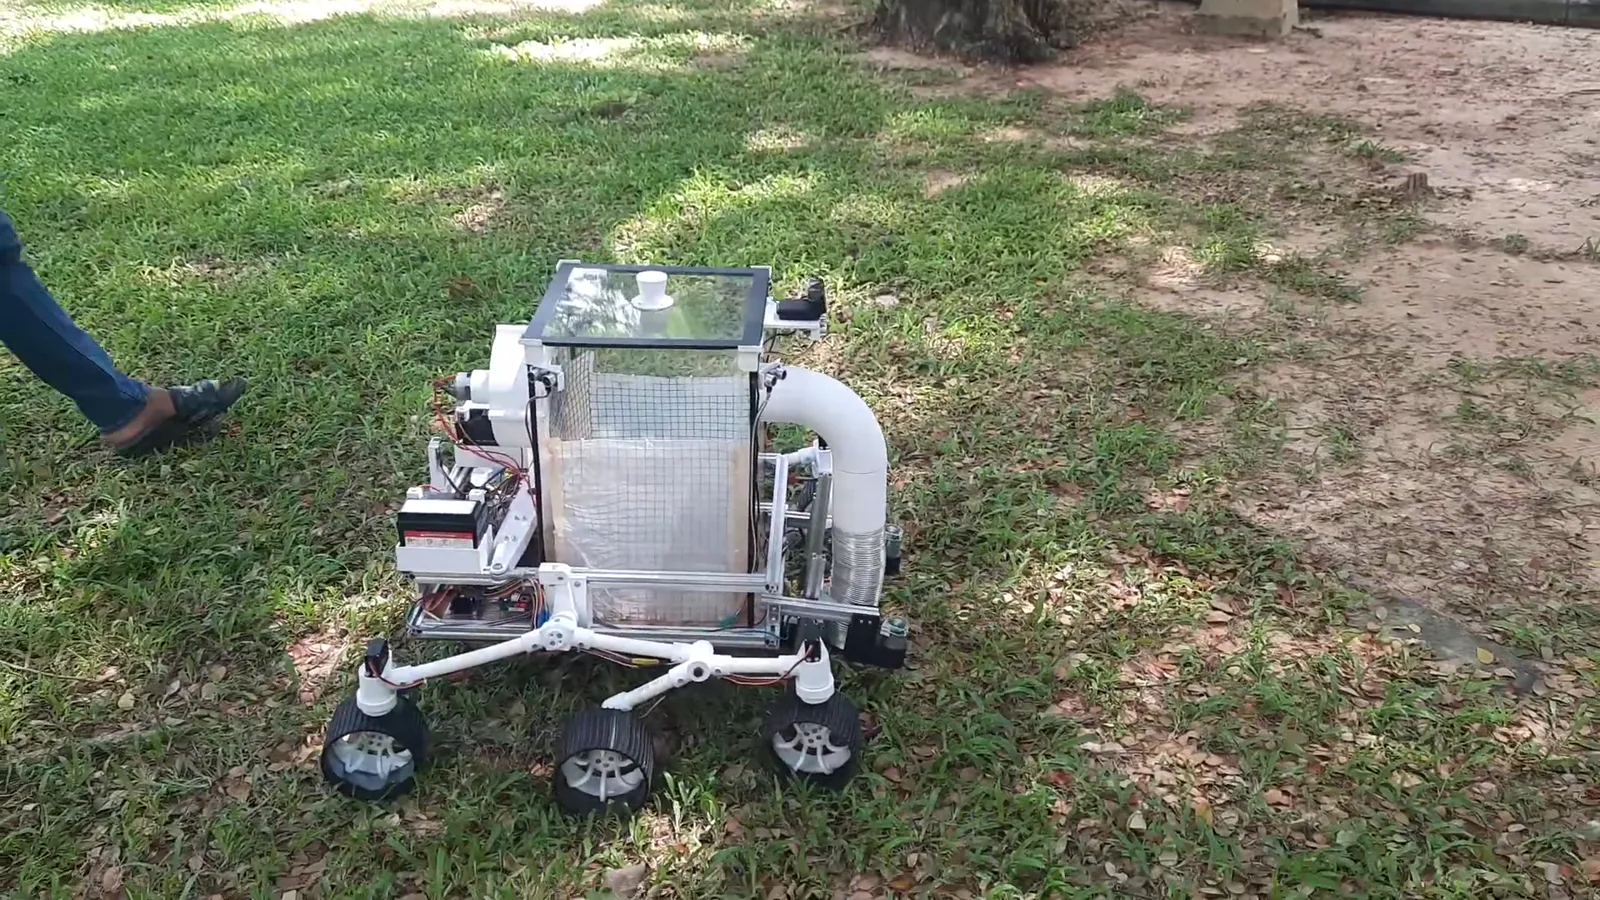
The Leave Collector Robot, a six-wheeled rocker-bogie rover with a vacuum duct and a mesh collection box, driving across grass
2023 — 2024 · KMITL

Leave Collector Robot

A rocker-bogie rover that vacuums leaves off grass, soil and pavement, and knows where it is by dead reckoning — wheel encoders for distance, a Kalman-fused gyro and magnetometer for heading, and a fine-tuned SAM that reads the ground ahead.

Kalman filterPIDDead reckoningAckermann steeringSAMRaspberry Pi + Arduino
Read the case study
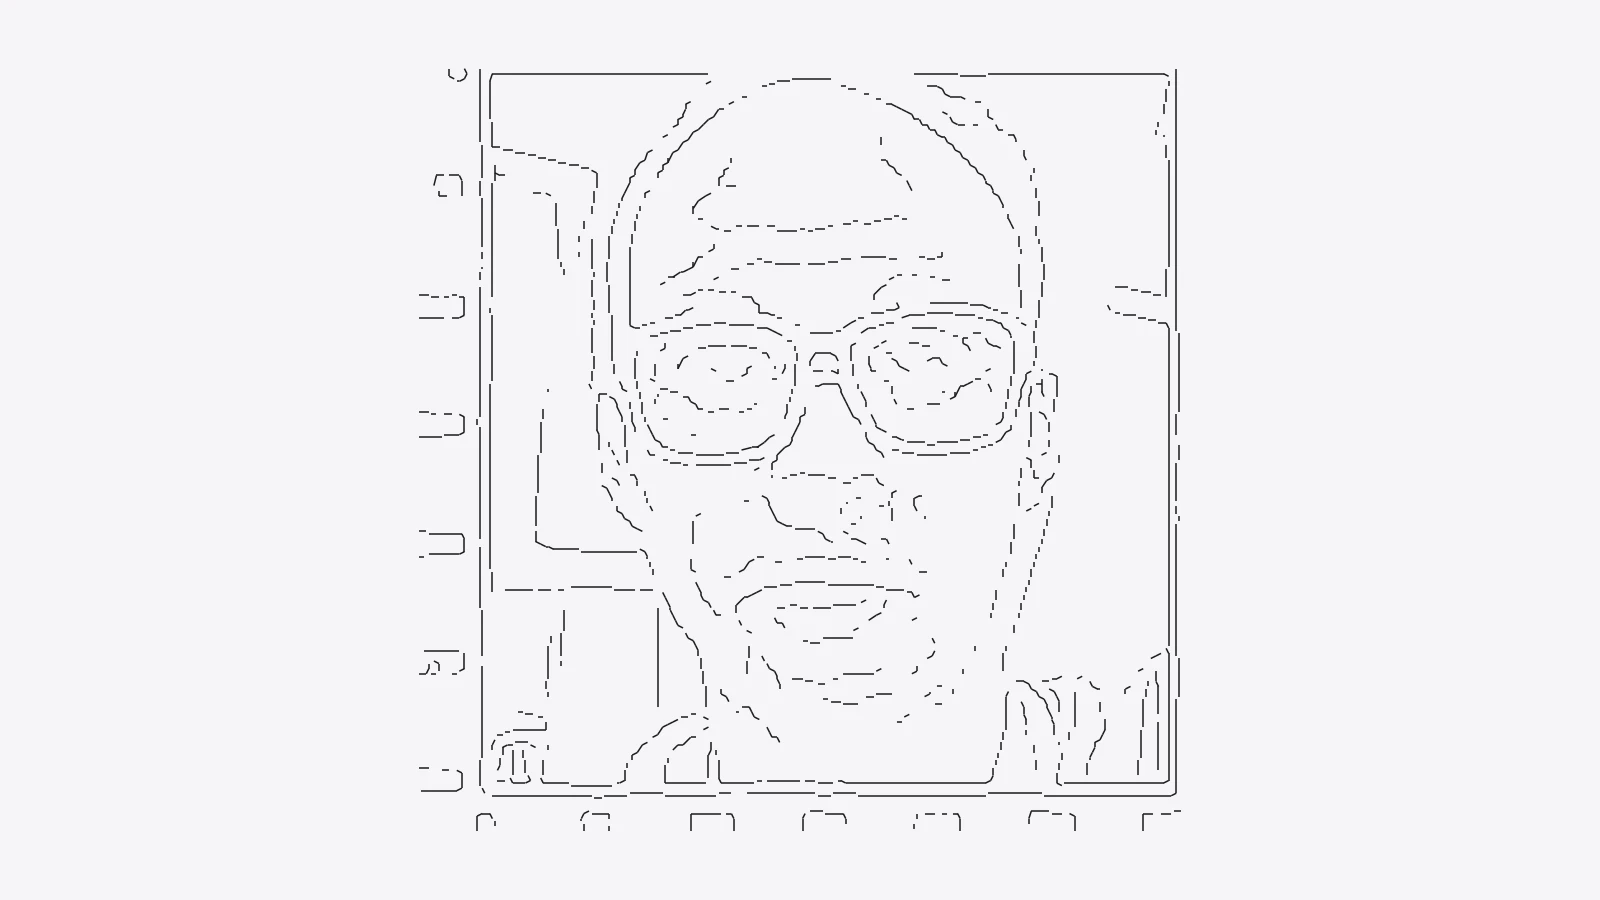
A portrait reduced to thin black contour strokes, the line drawing a pen plotter produces from a photograph
2024 · Personal

Portrait Drawing Robot

A pen plotter that photographs you and draws your portrait. Face detection and CLAHE clean the frame, Canny reduces it to one-pixel lines, and a circular-sampling vectoriser turns that bitmap into ordered G-code strokes.

OpenCVCLAHECannyGraph searchG-codeGRBL
Read the case study
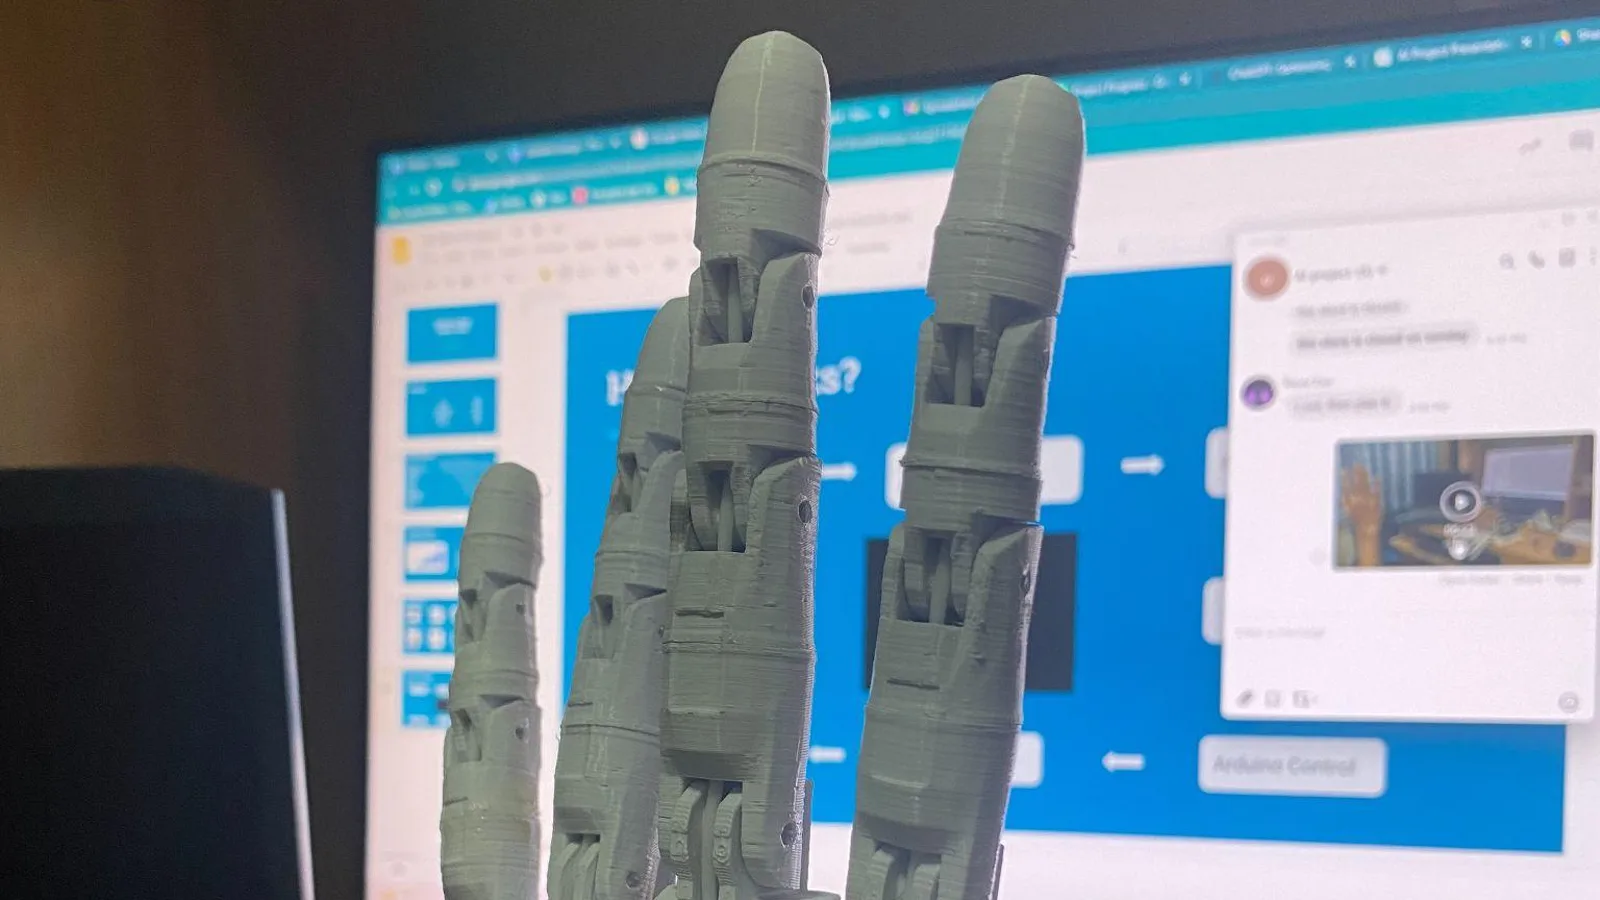
A 3D-printed robotic hand with its fingers extended, servo cables running from the wrist
2023 · KMITL

Gesture Controlled Robotic Hand

A printed hand that copies yours. MediaPipe turns a webcam frame into twenty-one landmarks, a geometric rule reduces those to five bits, and an Arduino drives five servos to match — thirty-two poses over a framed serial link.

MediaPipeTeachable MachineOpenCVpyserialArduino3D printing
Read the case study
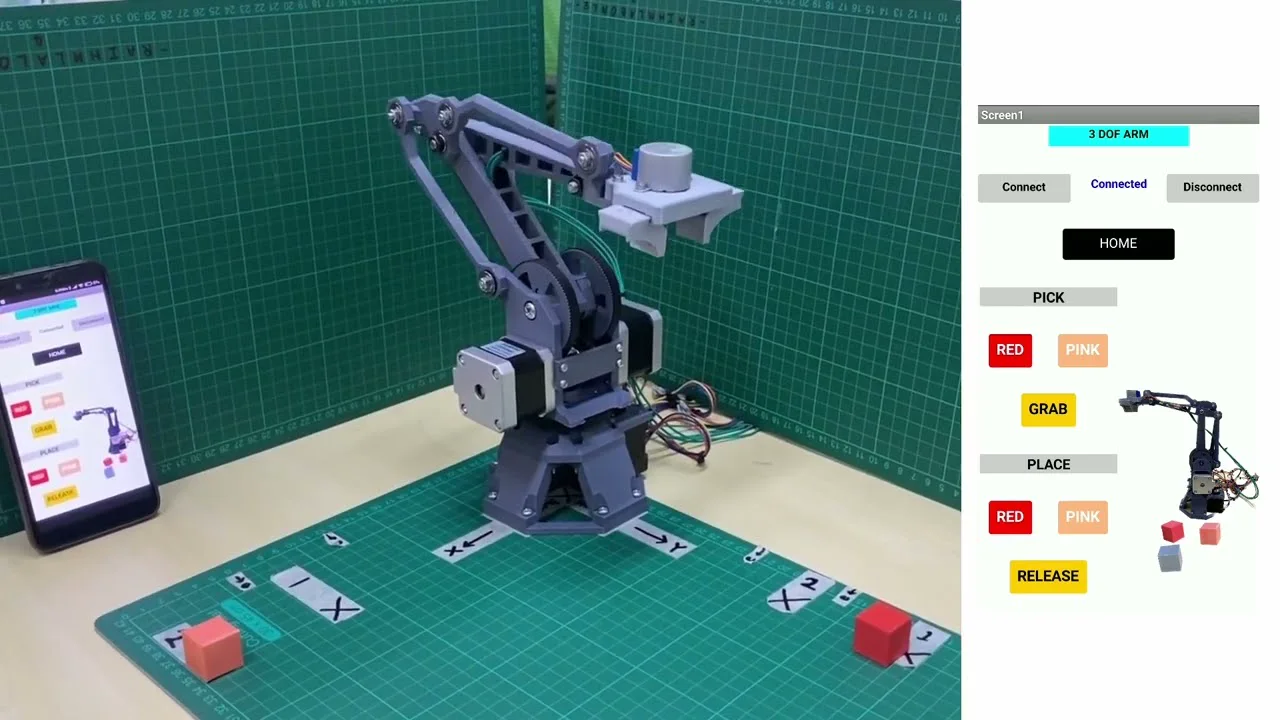
The three-jointed robot arm on a cutting mat beside a phone running its control app
2023 — 2024 · Final project

3-DOF Robot Arm

Three stepper joints and a gripper running pick-and-place from a phone, on a 3D-printer shield. Open loop: it homes against its own limit switches and then counts steps, with hand-authored joint waypoints instead of a planner.

Arduino MegaRAMPS 1.4SteppersLimit switchesBluetooth28BYJ-48
Read the case study
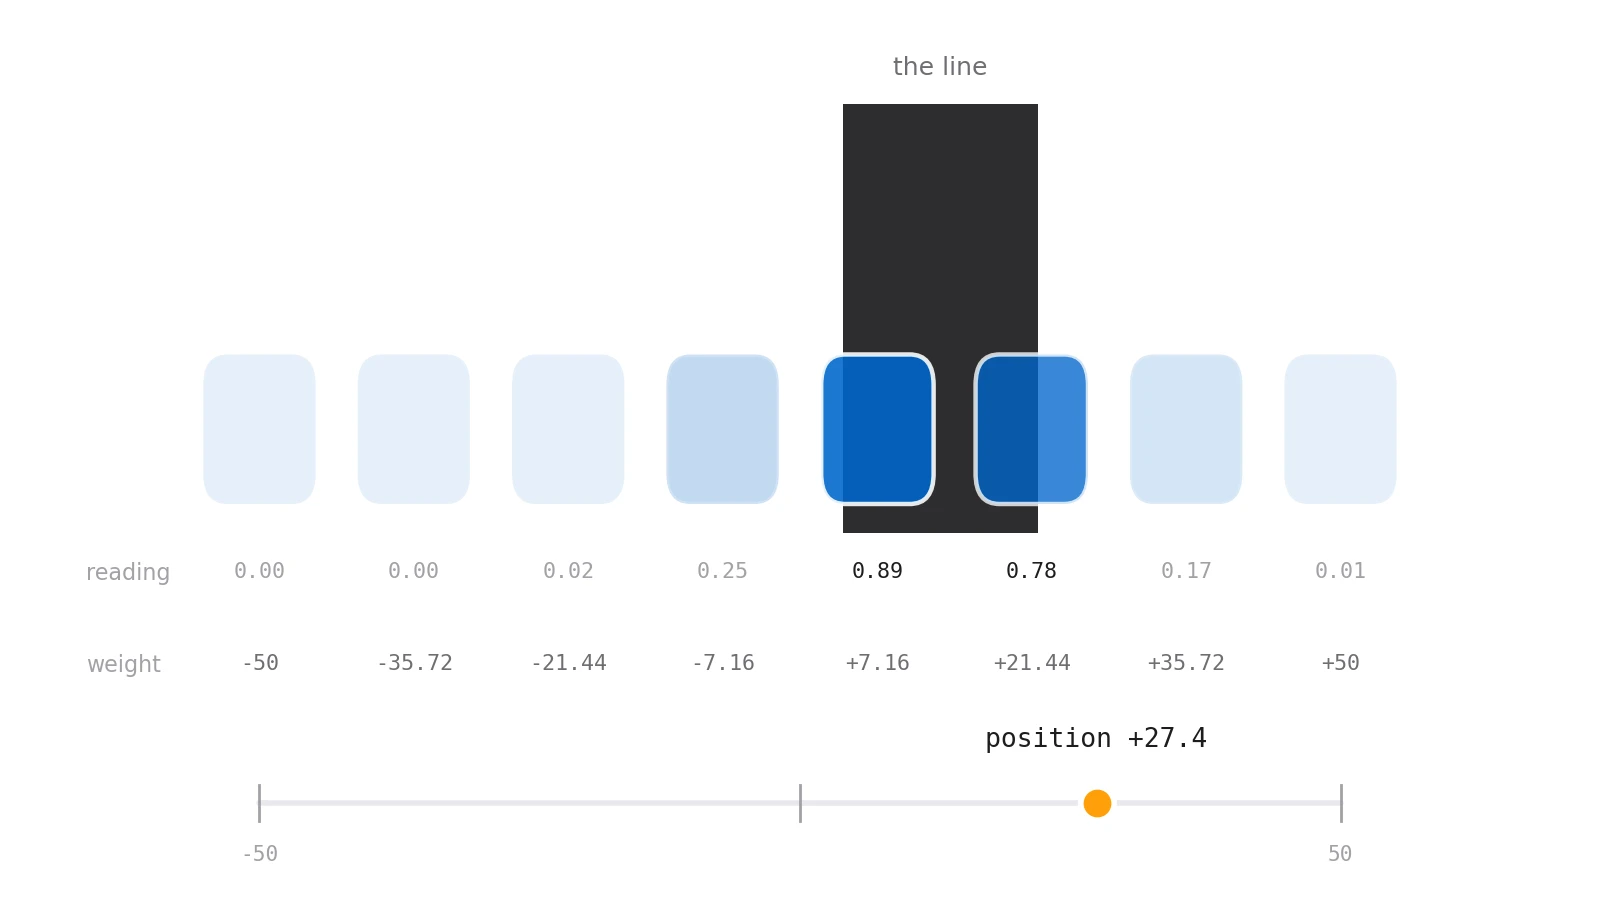
Diagram of the eight-sensor array reading a black line, with each sensor's weight and the resulting position
2023 · Embedded

STM32 Line Follower

Bare-metal on an STM32F411. Eight reflectance sensors calibrated per channel and read by free-running DMA, collapsed to one continuous position, steered by a 200 Hz PID — and a one-frame memory that turns a lost line into a recovery instead of a crash.

STM32F411HALADC + DMAPIDTimer PWMCubeIDE
Read the case study
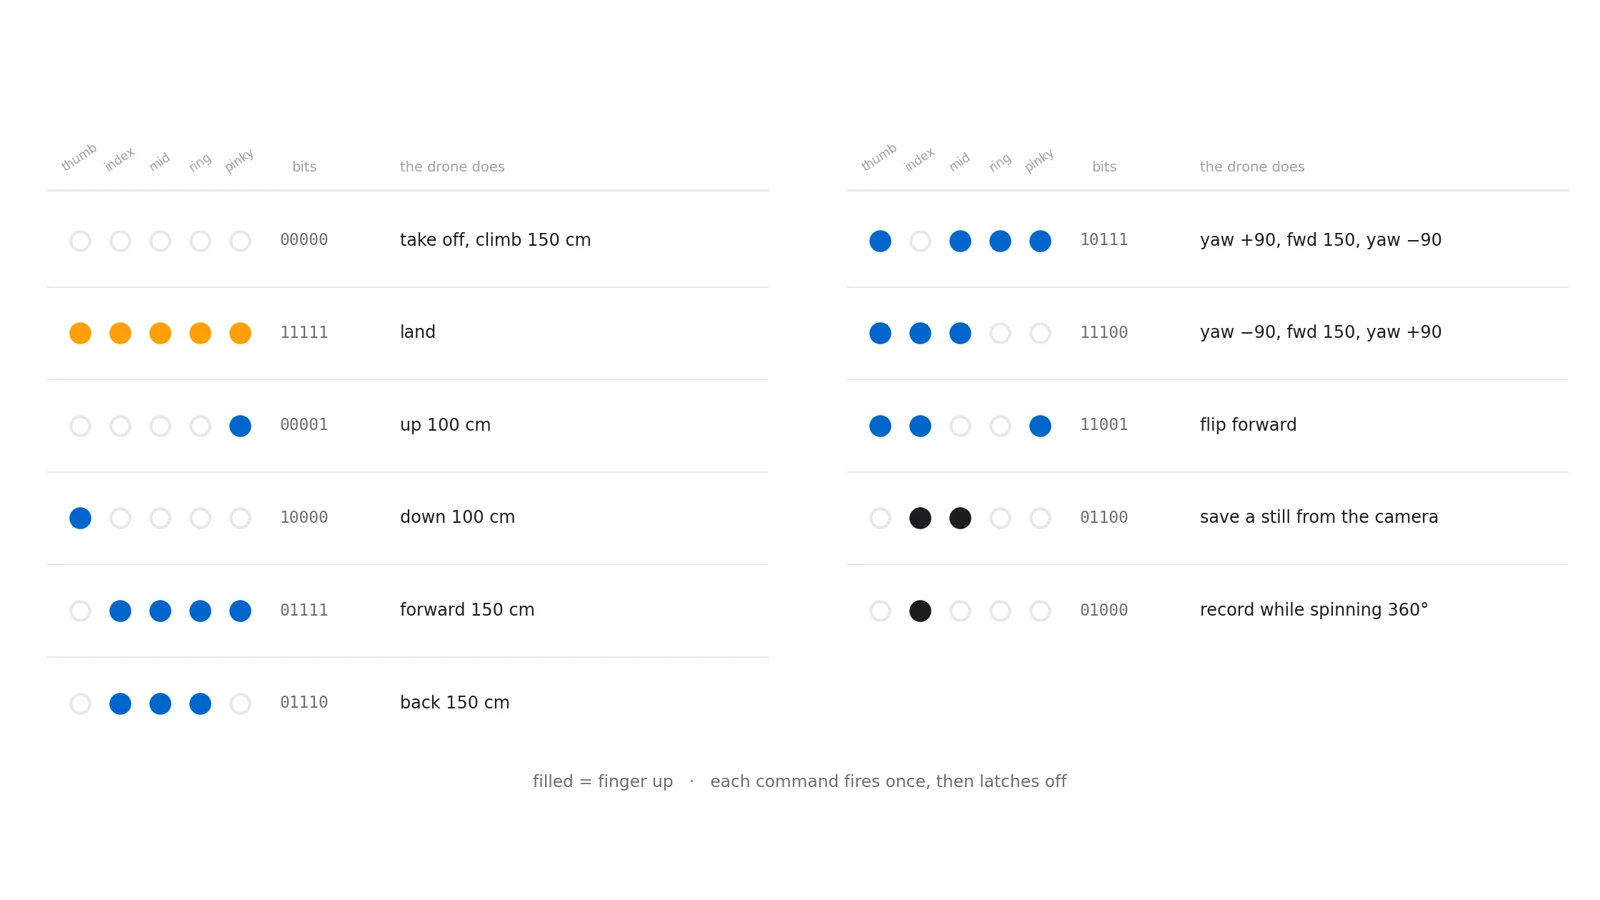
A table of eleven hand gestures shown as five dots each, with the drone command every pattern triggers
2023 · Computer vision

Tello Gesture Control

Flying a DJI Tello by hand. The gesture detector from the robotic hand project, lifted out as a module: the same five bits become an address into eleven drone commands — including one that makes the drone photograph the room, and one that films its own 360° turn.

MediaPipedjitellopyOpenCVThreadingTello SDK
Read the case study
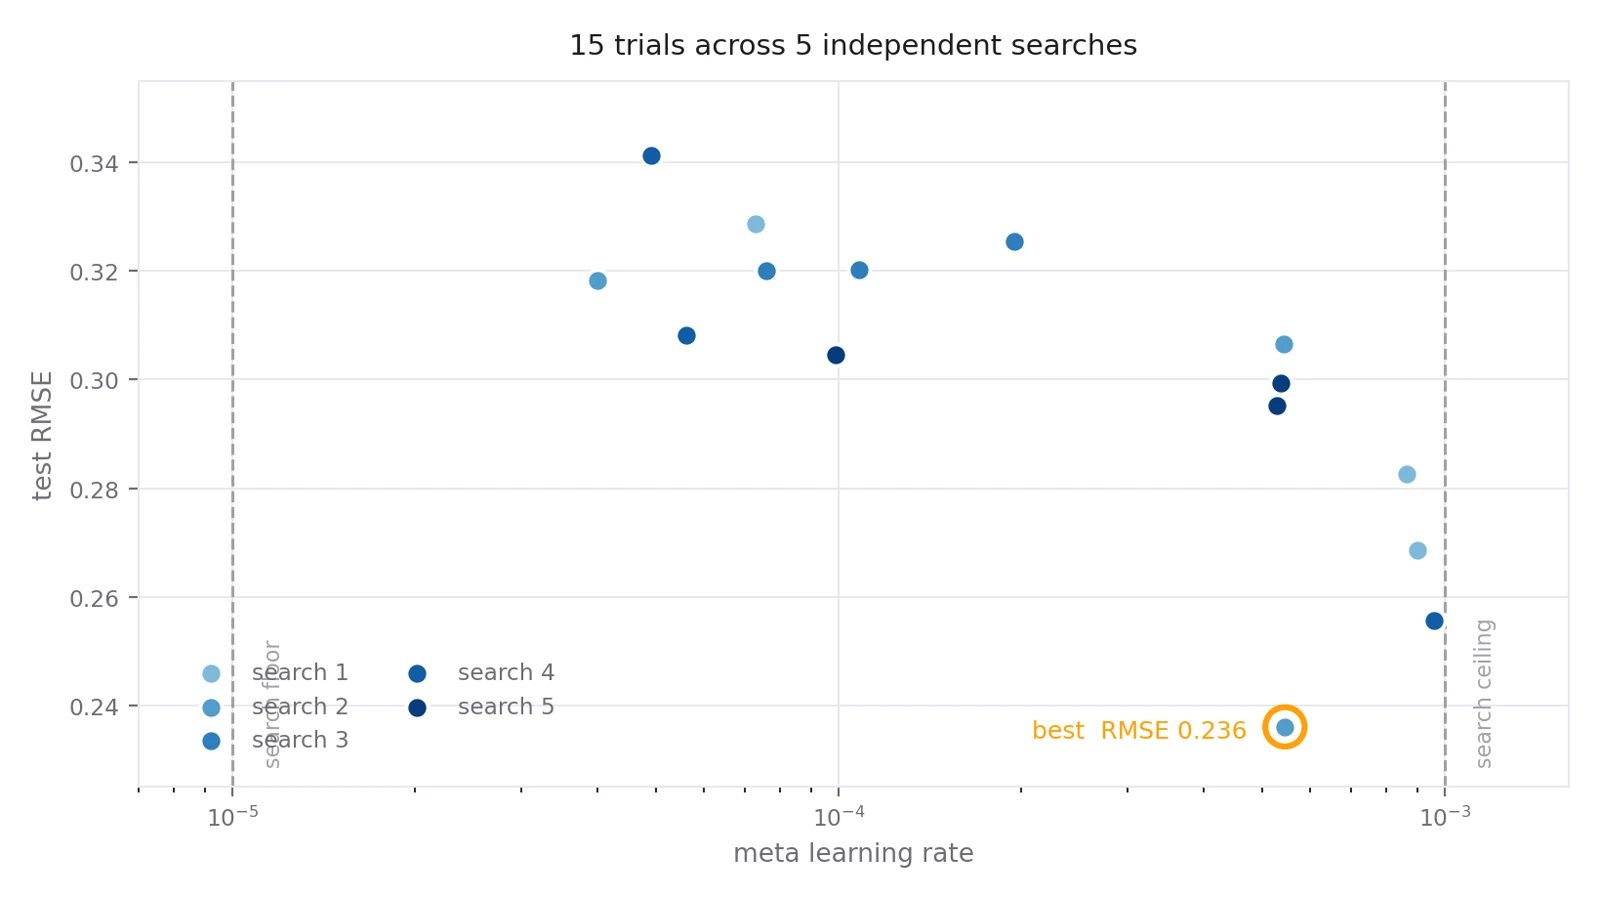
Scatter plot of test error against meta learning rate across fifteen tuning trials, with the best results crowded at the top of the searched range
2024 · Machine learning

Tuning a Meta-Learner

Handing the meta learning rate of a support/query learner to KerasTuner's Bayesian optimisation, then reading fifteen trials properly — the winners crowd the top of the range, which says the search was bounded too low rather than that it found an optimum.

TensorFlowKerasTunerMeta-learningBayesian optimisationColab
Read the case study
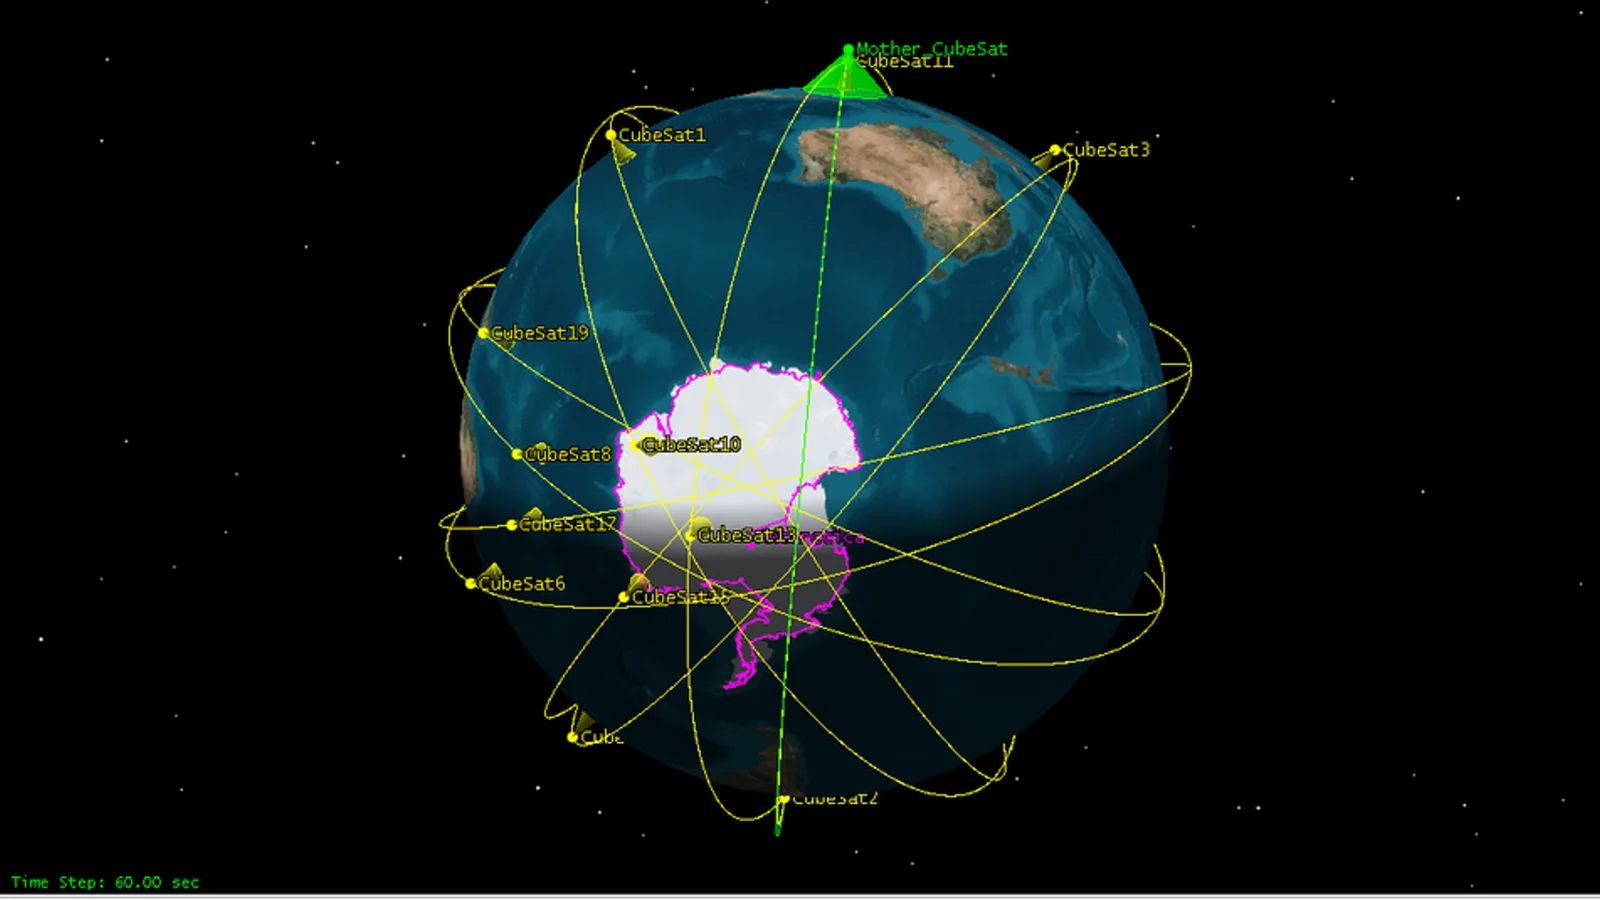
An STK view of Earth crossed by twenty CubeSat orbit tracks arching over the pole
2025 · KMITL

MyoSat1 Orbit Design

A CubeSat constellation for watching polar ice: a Walker Delta of twenty 3U observers at 97.8°, a sun-synchronous relay that decides what is worth downlinking, and 873 days of real CryoSat-2 retrievals run through the pipeline the mission would feed.

Ansys STKWalker DeltaCubeSatRemote sensingxarrayFlask
Read the case study

Skills.

Languages

  • Python
  • Modern C++
  • Rust

Control

  • Deep reinforcement learning
  • CPG gait generation
  • State estimation, EKF, VIO

Simulation

  • Isaac Sim and Isaac Lab
  • MuJoCo
  • Gazebo, RViz

Systems

  • ROS 2
  • SocketCAN
  • Real-time multithreading

Education.

2022 — 2026
King Mongkut's Institute of Technology Ladkrabang
B.Eng. Robotics and AI Engineering · GPA 3.6
2018 — 2021
University of Information Technology
B.Sc. Computer Science

Recognition.

2026
Humanoid bipedal leg with a natural walking gait
2025
Attended the ROS developer conference in Singapore
2024
Hult Prize Foundation
International hackathon on technology and sustainability
2023
Grand Prize, KTB Case
International summer school and hackathon

Let's build something that moves.